1 of 3 slides.
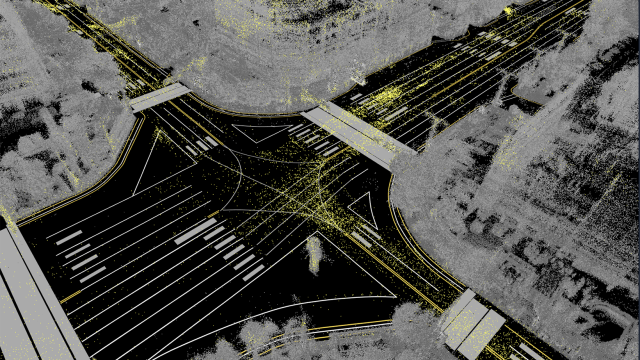
Additional Free Distribution of HD Map Datasets for Yeouido and Magok Areas
HD Map & Localization Dataset V1.0 (Yeouido)
HD Map & Localization Dataset V1.0 (Magok)
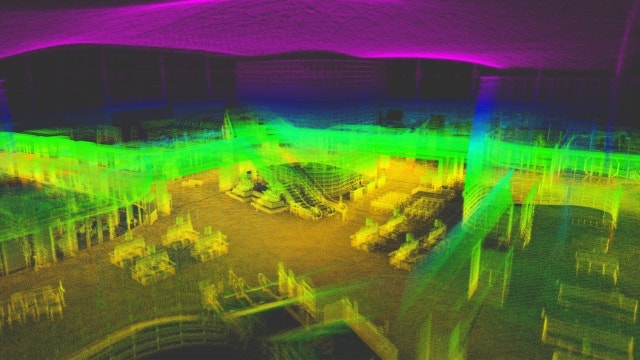
[Mapping & Localization Challenge] Dataset Building Process and the Visual Localization Baseline Techniques
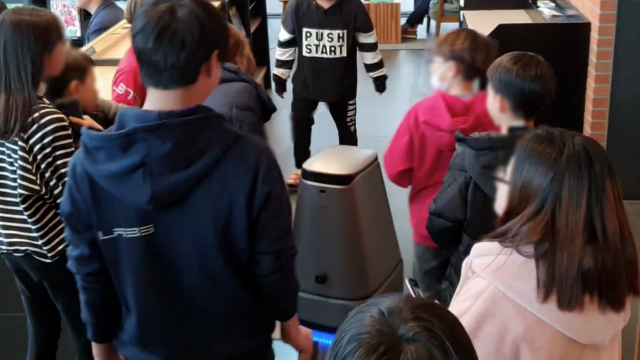
Enabling Robots to Learn Indoor Autonomous Driving Algorithms That Allow Them to Adapt to Various Settings and Tasks Through Reinforcement Learning
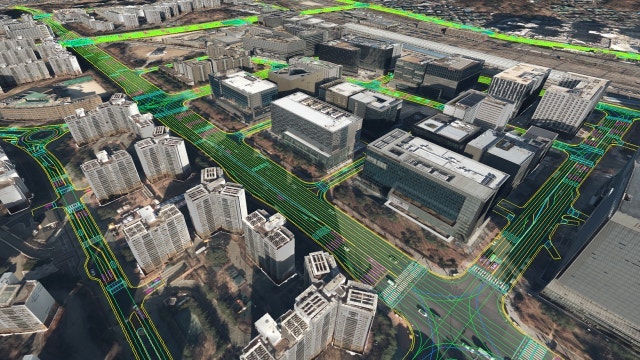
Aerial image based 3D modeling for HD mapping
High-Precision Synergies of Experts, Hybrid HD Mapping
Things NAVER LABS Europe Is Doing Now - Interviews with Key Researchers
“What Can Robots Do? Things That Smartphones Won’t Be Able to Do” – An Interview with MIT Professor Sangbae Kim

Indoor AR Navigation: How we developed a multi-floor demo at Hyundai Department Store–Pangyo
NAVER LABS’ 10 Defining Moments in 2019
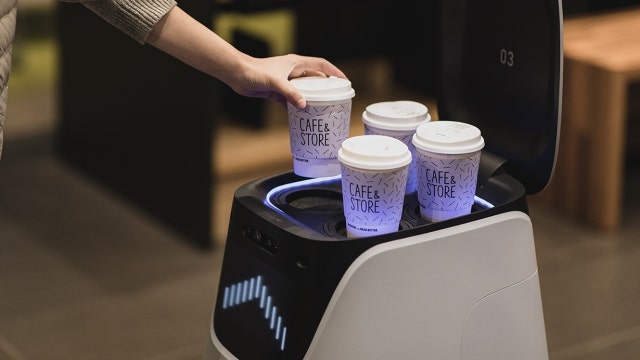
Human-Robot Interaction Tests on the AROUND C Cafe Delivery Robot